Fit the robot into your line and your budget
The software that ties robot, sensors and plant systems together, and the arm, gripper, cameras and compute chosen with evidence rather than from a catalogue.
- The time per command at 30 commands a second. A model that sometimes takes 90 ms will miss it.
- 33 msThe time per command at 30 commands a second. A model that sometimes takes 90 ms will miss it.
- NVIDIA’s July 2026 Jetson price rise. Tutorials quoting older prices are out of date; we budget with current ones.
- Up to 101%NVIDIA’s July 2026 Jetson price rise. Tutorials quoting older prices are out of date; we budget with current ones.
- A six-axis research arm (AgileX PiPER) today, in a price band that used to be empty.
- $1,999A six-axis research arm (AgileX PiPER) today, in a price band that used to be empty.
What we do
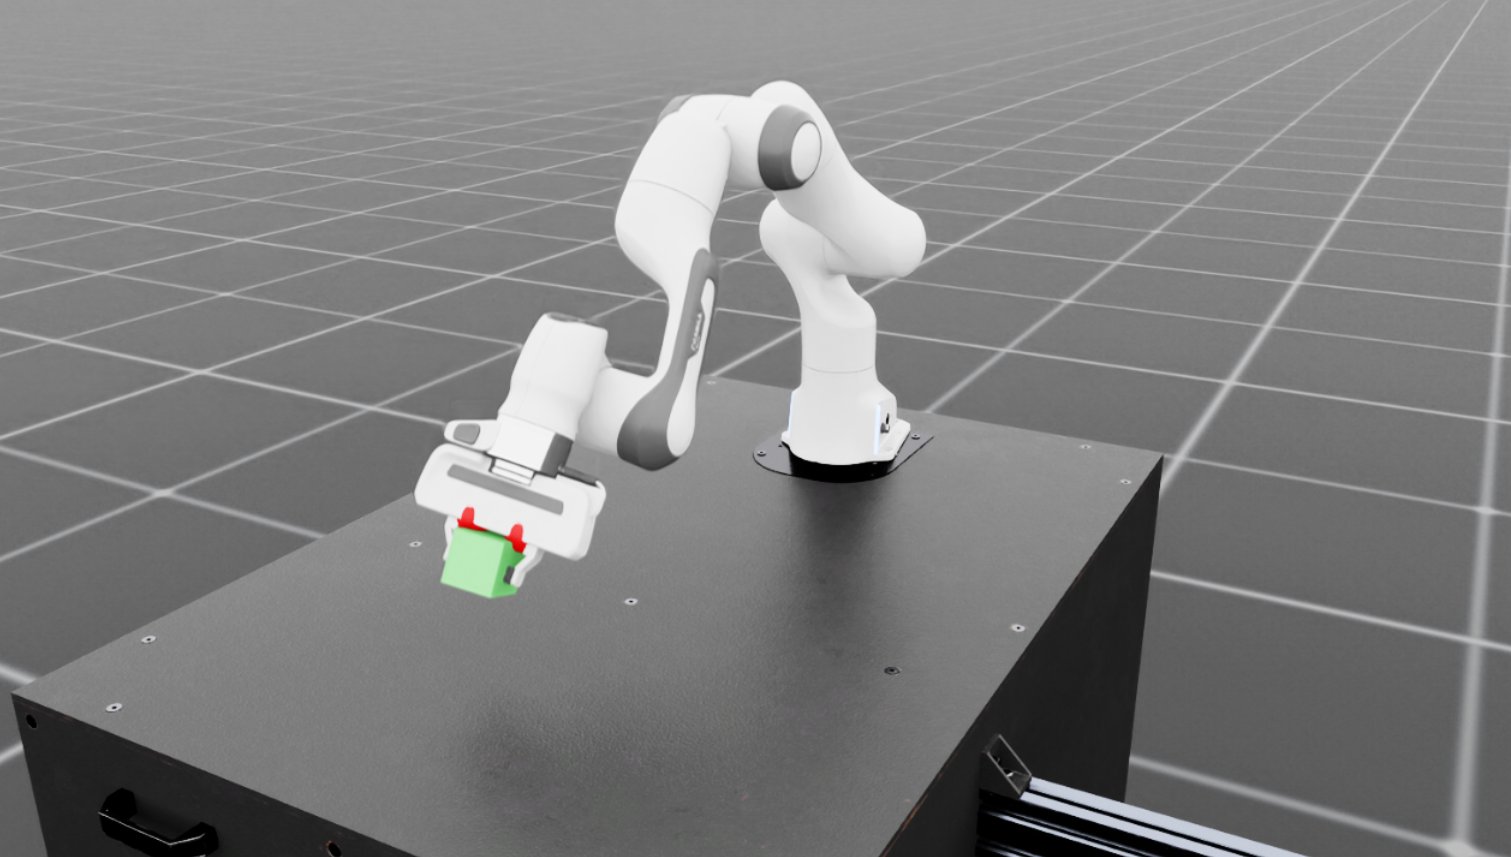
ROS and middleware integration
The software that ties robot, sensors and plant systems together.
- ROS 2 nodes, drivers and ros2_control
- Perception and planning exposed as services
- Bridges to PLCs and line controllers
- Containerized deployment, logging with rosbag2, and monitoring
Hardware selection
The right arm, gripper, cameras and compute, chosen with evidence.
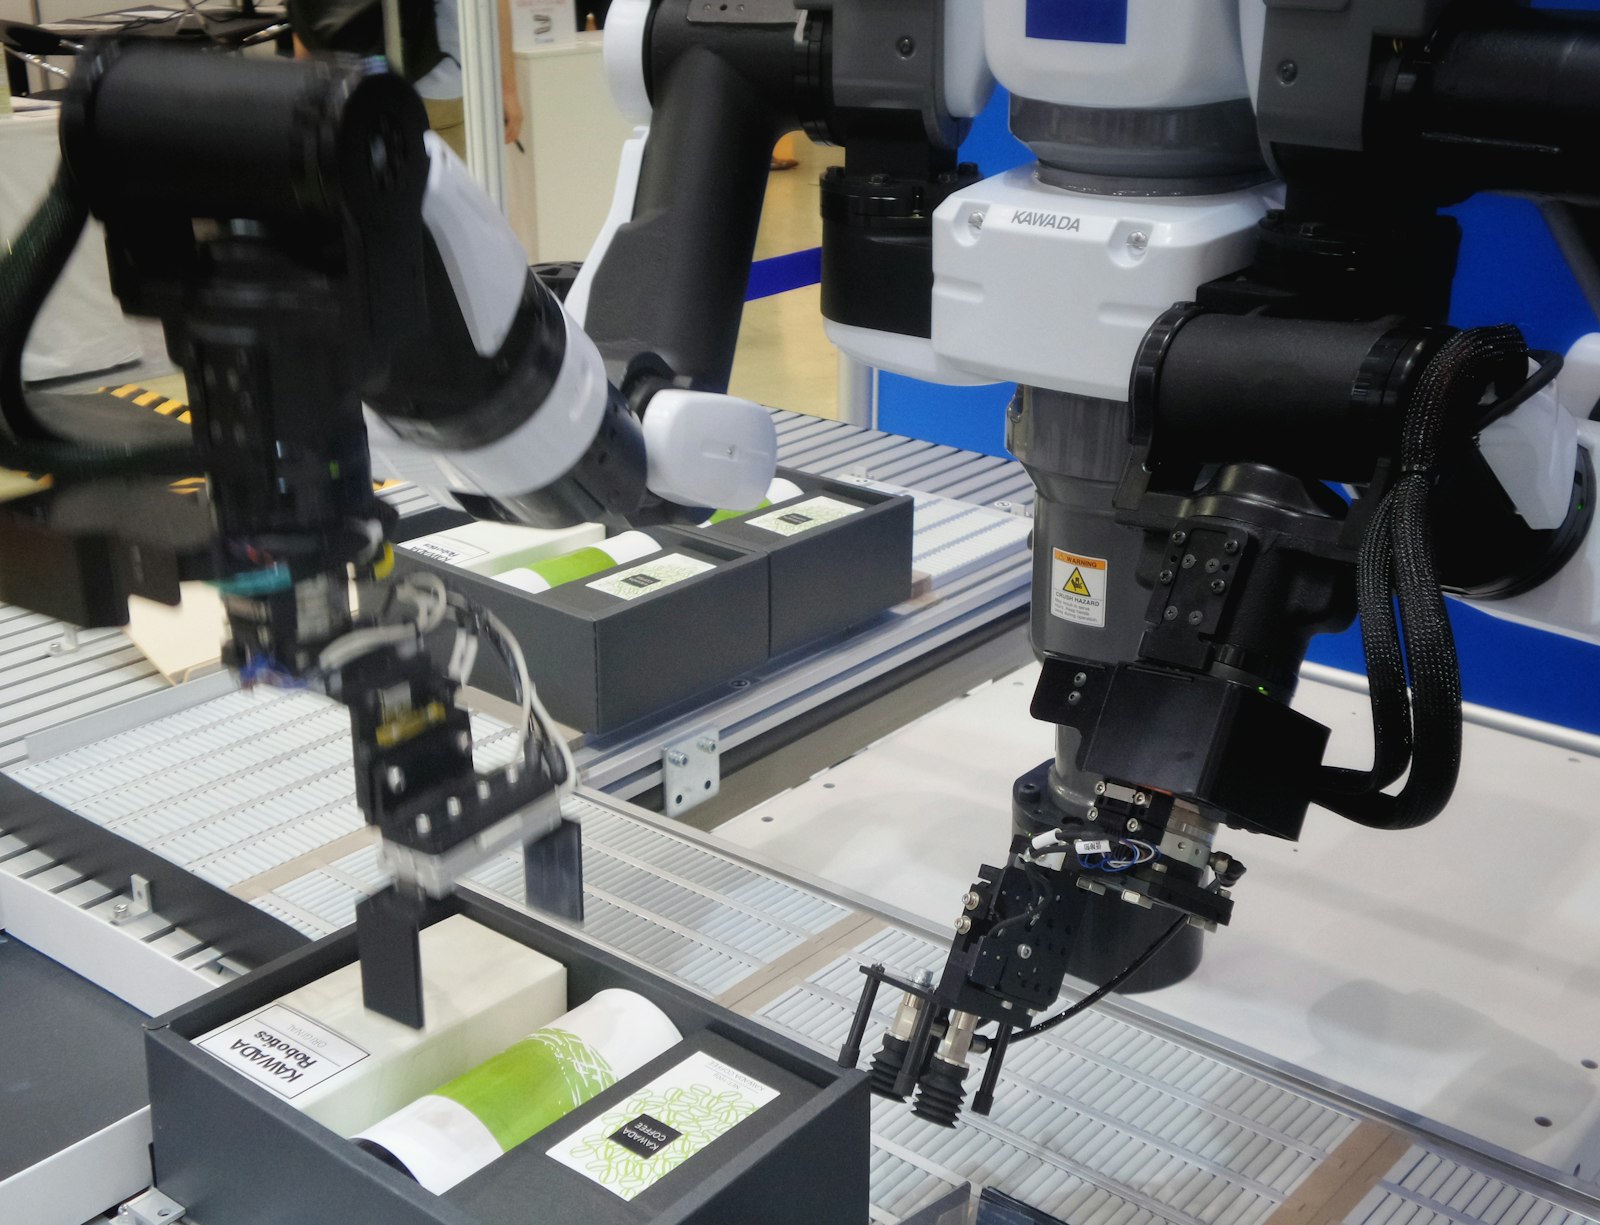
- Arms, grippers and end-effectors
- Cameras and lighting
- Training GPUs and on-robot compute
- Options compared in simulation before purchase
Model or no model
Where should the model run?
Programmed approach
- Real-time control loops on the robot controller
- Safety logic in certified hardware and PLCs
Learned approach
- Perception and policies on a GPU next to the cell
- Smaller models on Jetson-class compute on the robot
How we choose
We set a time budget for every loop first: for example 33 ms per camera frame and 2 ms per tick of a 500 Hz controller. Then we pick the compute that meets it every time, not on average, within your network and power limits.
Example hardware we compare
List prices from our notes, September 2026. We compare options in simulation before you buy.
| Item | What it is | List price |
|---|---|---|
| AgileX PiPER | 6-axis arm, 1.5 kg payload | $1,999 |
| UFACTORY xArm 6 | 6-axis arm | About $8,400 to $8,600 |
| NVIDIA Jetson Orin Nano Super | On-robot compute for small models | $399 |
| NVIDIA Jetson AGX Thor | On-robot compute for larger models | $5,499 |
Prices change often. We re-check them for every project.
Tools we use
- ROS 2 Jazzy
- ros2_control
- MoveIt 2
- rosbag2
- Docker
- NVIDIA Jetson
- OPC UA / PLC bridges
What you get
- A hardware shortlist with evidence
- ROS 2 integration with your line
- Deployment, monitoring and handover documentation
Read more in our notes